O Guia Definitivo para Escolher Entre Atuadores Lineares de 12V e 24V
Compare 12V and 24V linear actuator architectures using load, current, voltage drop, cable length, controller compatibility, duty cycle and selected-build evidence.
Voltage is one part of linear-actuator system selection. Choose it together with the selected actuator configuration, load, speed, duty cycle, current, cable length, power source, controller, feedback, mounting and environment rather than treating 12V or 24V as a shortcut to performance.
Este guia abrangente detalha tudo que você precisa saber sobre a seleção de tensão, desde a física fundamental até considerações práticas de aplicação, ajudando você a tomar uma decisão informada para seu caso de uso específico.
Tabela de Conteúdos
Compreendendo a tensão em atuadores lineares
Linear actuators convert electrical energy into linear motion. Supply voltage defines part of the electrical operating point, but actuator thrust, speed, efficiency and thermal behavior also depend on the motor, gearing, screw, current limits, controller, load and selected configuration.
Em sua essência, a energia elétrica segue uma fórmula simples:
Potência (W) = Tensão (V) × Corrente (A)
For the same electrical power, an ideal 24V load would draw half the current of a 12V load. Real actuator current still depends on motor design, efficiency, load, speed and controller behavior, so compare the actual rated and peak current of the selected build.
A física se torna ainda mais importante ao considerar as perdas nos fios. A resistência elétrica na fiação faz com que a energia seja perdida como calor, seguindo a fórmula:
Energia Perdida = I²R
Because resistive wiring loss follows I²R, halving current would reduce I²R loss to one quarter when conductor resistance and operating conditions are otherwise the same. Use actual current, round-trip conductor resistance and allowable voltage drop to size the harness; do not apply a fixed savings percentage across unlike actuator designs. For conductor identification and feedback connections, see the linear actuator wiring guide.
Comparação Técnica: Atuadores Lineares de 12V vs 24V
Empuxo e Saída de Força
Higher nominal voltage does not by itself establish actuator thrust. Rated load depends on the complete motor, gearing, screw, current limit, efficiency, duty cycle and mechanical design. Even when a product family has 12V and 24V variants, compare the approved specification for each selected configuration rather than assuming identical force.
Lower current at a similar electrical power level can help some wiring and driver designs, but it does not prove a higher continuous load or duty cycle. Continuous-load capability and thermal limits must come from the selected actuator’s documented rating and test conditions.
Current ActuLift product evidence treats the IP80 and relevant 12V actuator configurations as project-specific platforms. Use approved load, stroke, speed, duty-cycle and controller data rather than inferring “heavy duty” or “light duty” from voltage alone.
Desempenho de Velocidade
Actuator speed is configuration-specific. Two voltage variants may or may not use the same motor, gearing, screw or controller limits, so neither identical speed nor higher 24V speed should be assumed. Compare speed at the required load and supply conditions for the selected build.
If movement time matters, define the required stroke time and load, then compare candidate configurations. The HR61 likewise requires load, stroke, speed and duty cycle to be confirmed for the selected configuration; its compact size does not establish a generic speed class.
Comprimento do Cabo e Distância de Fiação
Talvez a consideração mais prática para muitas instalações seja quão longe você pode correr a fiação da fonte de energia até o atuador. É aqui que a física que discutimos anteriormente se torna imediatamente relevante.
Sistemas de 12V can require higher current than a similar-power 24V architecture. There is no universal 15-foot cable limit: calculate actual round-trip conductor resistance, rated/peak current, allowable voltage drop, connector losses and thermal constraints.
Sistemas de 24V may provide more voltage-drop margin at similar power because the current can be lower, but cable length is still an engineering calculation. Conductor size, peak current, connectors, controller limits, allowable drop and installation temperature determine the acceptable run.
Adequação da Aplicação: Quando Escolher Cada Tensão
12V Systems: When a 12V Architecture Fits
A 12V actuator can be a candidate when the equipment already has a suitable 12V electrical architecture and the selected actuator/controller can meet the required load, speed, duty cycle, current and environmental conditions.
Evaluate when:
The equipment has an approved 12V supply or battery architecture
The selected actuator and electrical system are validated for the actual environment; 12V alone does not establish marine suitability
The power source can supply rated and peak actuator current across the intended operating range
The harness is sized from current, length, allowable voltage drop and installation conditions
The selected 12V configuration meets the required load, speed and duty cycle
The controller, feedback and wiring are electrically compatible with the selected actuator
Mounting, environmental protection, documentation and system validation requirements are confirmed
Use the Atuadores Lineares 12V category to discover candidate products, then confirm voltage range, current, load, stroke, speed, duty cycle, controller and environmental evidence for the selected build.
24V Systems: When a 24V Architecture Fits
A 24V actuator can be a candidate when the equipment already uses a compatible 24V power architecture or when a lower-current electrical design is useful. Industrial or PLC use does not by itself make a 24V actuator the correct choice.
Evaluate when:
The equipment has an approved 24V supply sized for the actuator’s rated and peak current
Lower current at similar electrical power materially helps harness or driver design
The selected actuator build is approved for the required voltage, load, speed and duty cycle
Any care-related or regulated use is validated at the finished-system level; voltage does not establish medical suitability
Any aerospace or other regulated application receives project-specific qualification and documentation review
The multi-actuator controller, feedback, wiring, calibration and permitted synchronization error are validated independently of voltage
Harness length and voltage drop are verified by calculation using actual current and conductor resistance
PLC/controller interfaces, motor driver, isolation, current capacity and control logic are explicitly compatible
Use the Atuadores Lineares 24V category to discover candidate products. A category label does not establish continuous-duty, industrial, synchronization or environmental performance; confirm the selected build.
A Defesa da Sincronização de Múltiplos Atuadores
Multi-actuator systems need a defined synchronization architecture, but voltage alone does not determine synchronization accuracy. Start with the required channel count, actuator matching, feedback method, controller, wiring, load balance, calibration and permitted position error.
At similar electrical power, a 24V architecture may reduce branch current and can help power-distribution planning. That benefit is separate from synchronization performance: a 24V controller or PLC does not inherently provide more precise actuator synchronization.
For synchronized platforms or lifting systems, select the voltage that matches the approved actuator/controller architecture, then validate synchronization and fault behavior on the complete mechanism.
Integração de PLC e Controle Industrial
Many industrial control systems use 24V DC for sensors, I/O or control power, but actuator motor supply and PLC signal voltage are separate design questions. Confirm the exact interfaces before integration:
Signal compatibility: verify controller/PLC input and output levels, interface type, grounding and isolation requirements
Power separation: do not assume an actuator motor can be powered directly from a PLC output; use the required driver or control box
Current and protection: size the power supply, driver, fusing and wiring for rated, peak and fault conditions
EMC / machine safety: address transients, shielding, grounding, protective functions and applicable equipment requirements at system level
O IP80 is a 24V actuator platform, but PLC or controller compatibility still requires confirmation of motor-driver current, control interface, feedback, wiring and fault behavior for the selected configuration.
Avisos Críticos: Desajuste de Tensão
Nunca Exceda a Tensão Nominal
Aplicar uma tensão superior à classificação do atuador pode causar danos imediatos e severos. A sobretensão leva a um consumo excessivo de corrente, superaquecimento, falha do enrolamento do motor e falha completa do atuador—frequentemente dentro de segundos. Nunca conecte um atuador de 24V a uma fonte de energia de 24V que oscile acima da tensão nominal e sempre use regulação de tensão apropriada.
Riscos de Subtensão
Embora menos destrutiva imediata, a subtensão também pode causar problemas. Quando um atuador recebe tensão insuficiente, ele pode:
Parar sob carga, consumindo corrente excessiva e superaquecendo
Falhar em completar golpes de forma confiável
Experimentar desgaste prematuro devido ao aumento do estresse mecânico
Operar de forma inconsistente, dificultando o controle do sistema
A Polaridade Importa
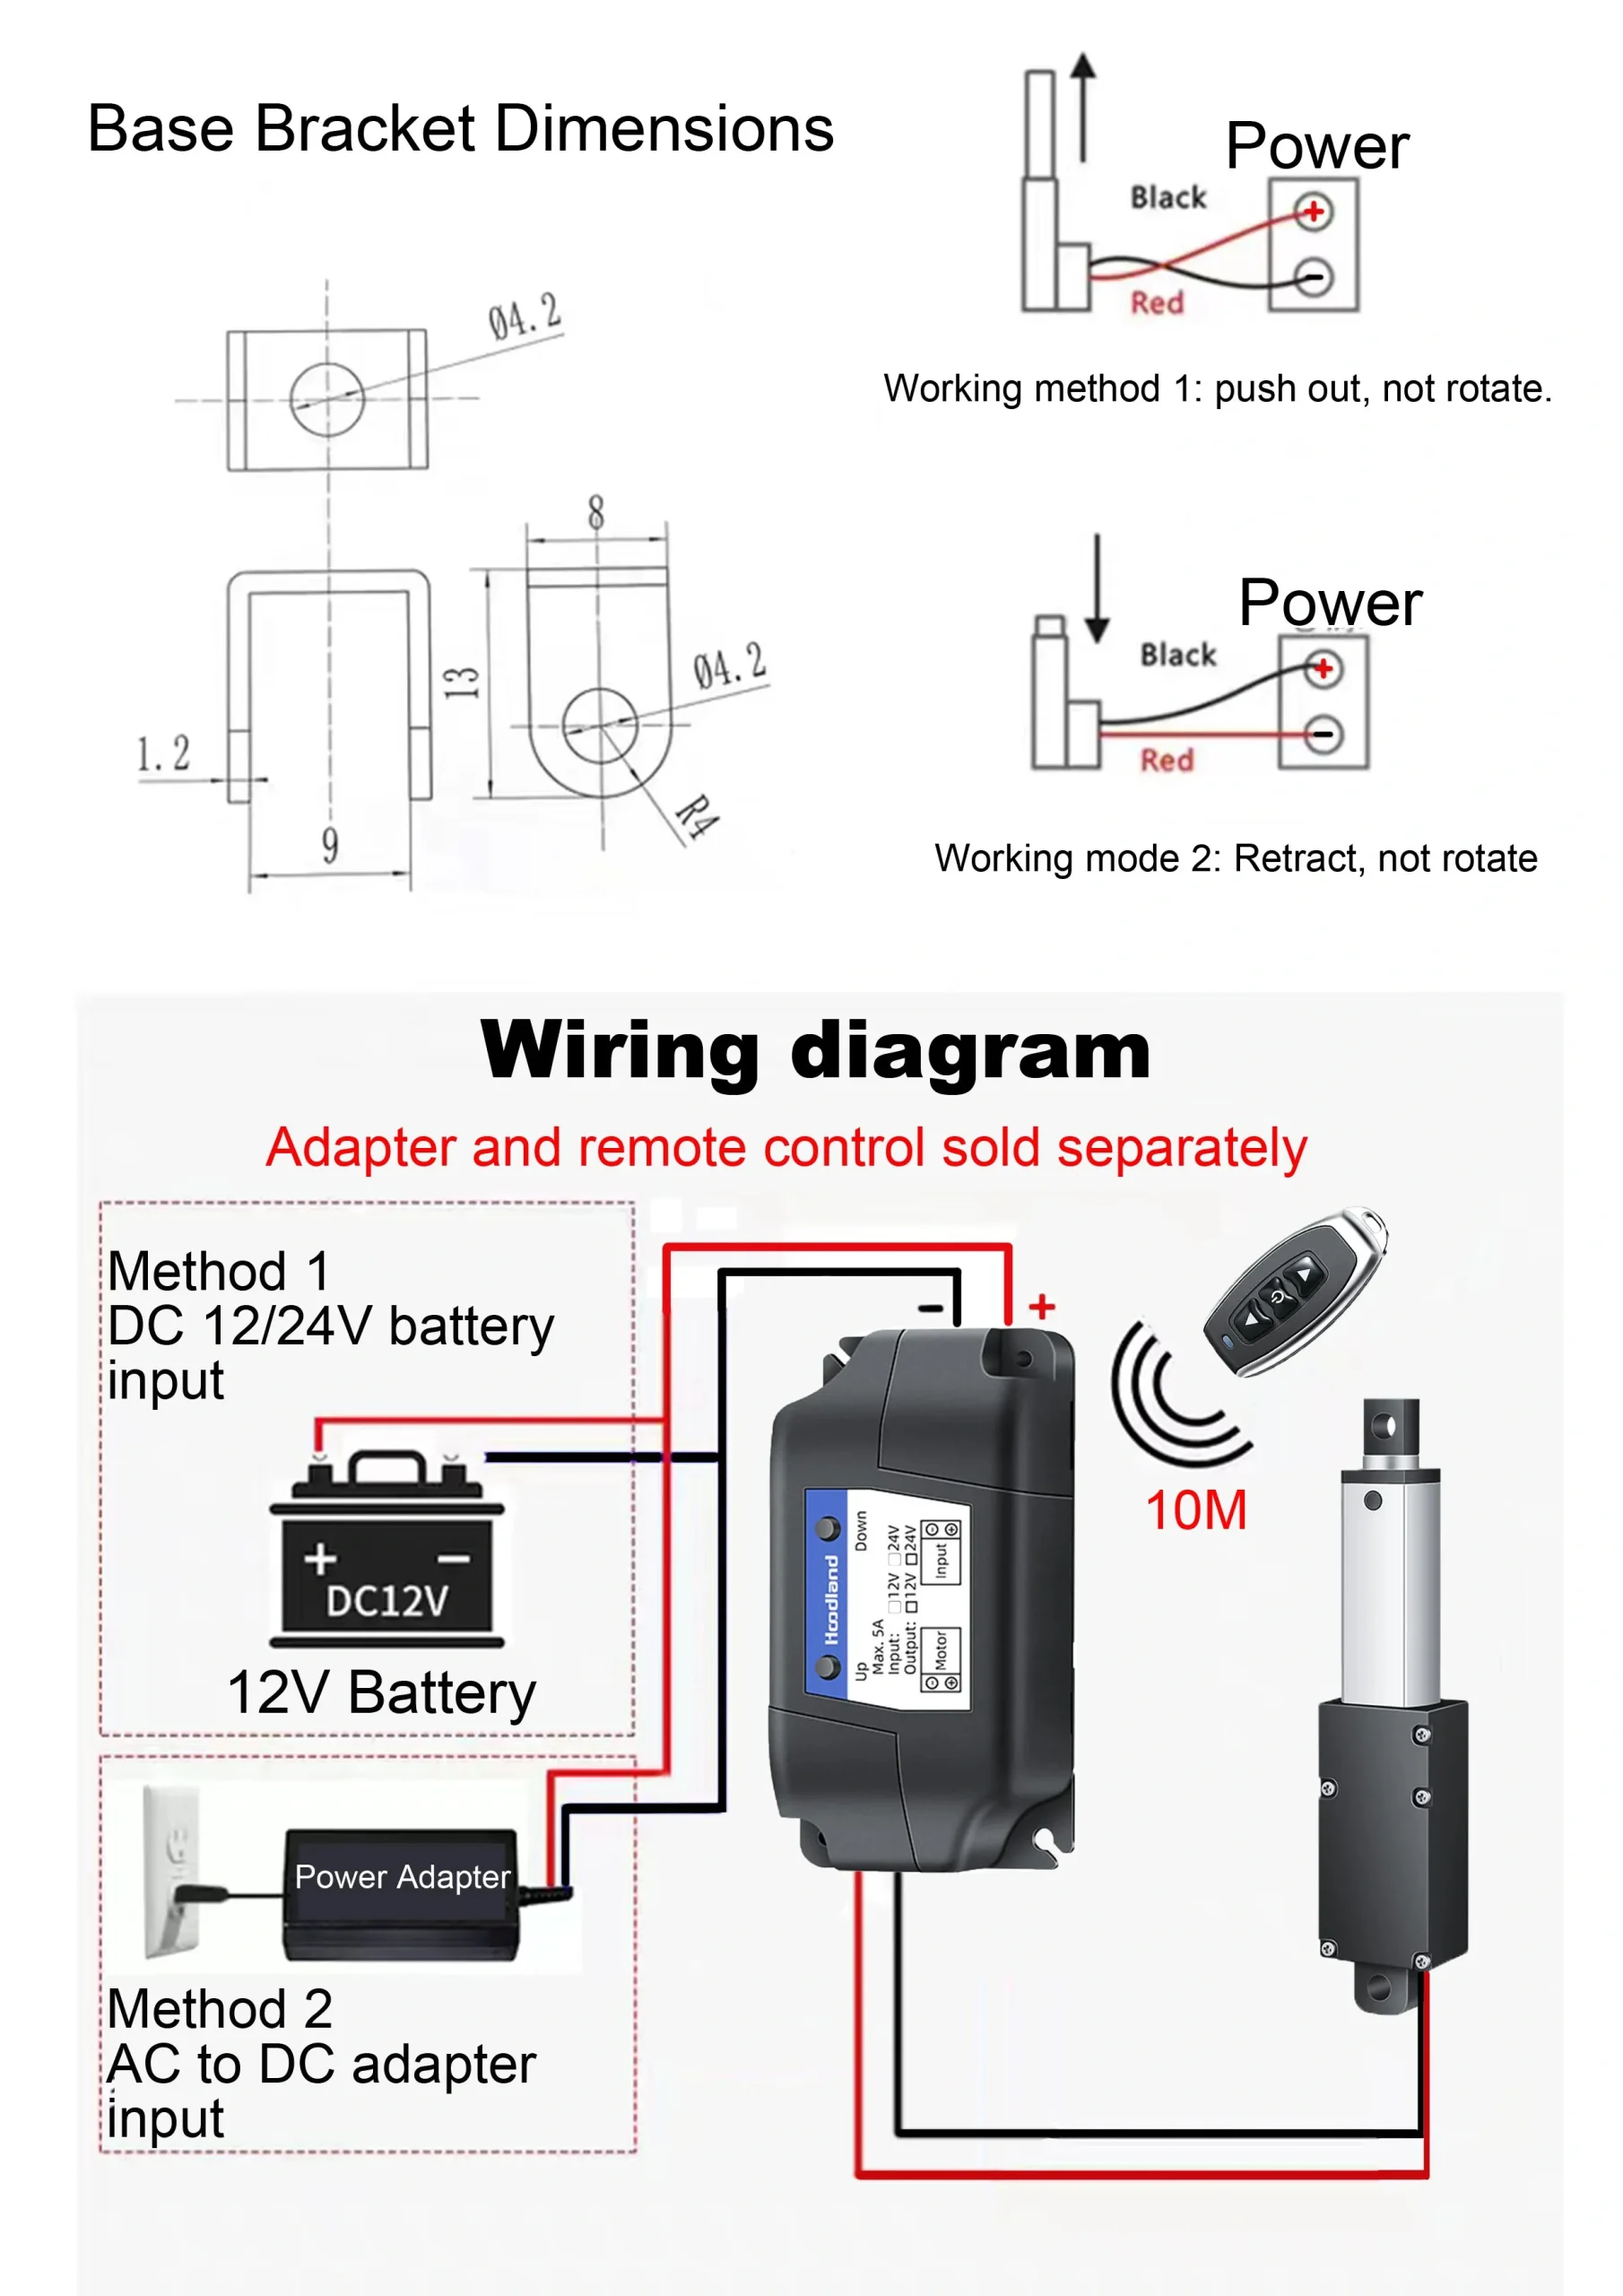
Para atuadores lineares DC, a polaridade correta é essencial. A polaridade reversa pode fazer com que o atuador funcione ao contrário, podendo criar perigos de segurança na sua aplicação. Em alguns casos, a inversão da polaridade pode também danificar a eletrônica de controle.
Recomendações para Operação Segura
Sempre verifique as classificações de tensão antes de conectar a energia
Utilize fontes de energia apropriadas com regulação de tensão adequada
Inclua fusíveis apropriados para proteger contra condições de falha
Provide surge/transient protection where required by the power architecture and installation environment
Siga as diretrizes de instalação do fabricante precisamente
Commission within the documented supply range and follow current-limit and test requirements for the selected product
Fazendo Sua Seleção: Uma Estrutura de Decisão Prática
Escolher entre atuadores lineares de 12V e 24V não precisa ser complicado. Considere esta estrutura de decisão:
Evaluate 12V when:
The equipment already provides a compatible, regulated 12V architecture
Calculated voltage drop and conductor heating are acceptable for the actual harness
The selected 12V configuration meets the required load and holding conditions
The selected 12V configuration meets the required speed under load
Power-supply, controller, wiring and lifecycle tradeoffs have been compared for the project
The controller and power source are sized for the actuator’s rated and peak current
Environmental, mounting and safety requirements remain within the selected product’s documented limits
Evaluate 24V when:
The equipment already provides a compatible 24V power architecture
Lower current at similar power helps the calculated harness/voltage-drop design
The selected 24V configuration—not the voltage label—meets the required load and duty cycle
The selected 24V configuration meets the required speed at the real load
The chosen multi-actuator controller/feedback architecture is compatible and validated
The motor driver and PLC/controller interfaces are explicitly compatible
The selected actuator has a documented duty/thermal rating that matches the operating cycle
Posso operar um atuador linear de 12V em uma fonte de alimentação de 24V?
Do not do so unless the actuator or its approved controller documentation explicitly allows that supply range. Use the rated supply and protection requirements for the selected configuration; overvoltage can damage the motor or integrated electronics.
Um atuador de 24V fornece mais força de empurrão do que uma versão de 12V?
Not inherently. Force depends on the complete actuator design and selected configuration, including motor, gearing, screw, current limits and duty cycle. Compare the approved load specification for the exact 12V or 24V build.
Does 24V always permit longer cable runs?
No fixed distance follows from voltage alone. At the same electrical power and conductor resistance, 24V can reduce current and I²R loss, but the allowable run must be calculated from actual rated/peak current, wire size, round-trip resistance, connectors and permitted voltage drop.
When does 12V make sense for battery-powered equipment?
12V can simplify integration when the equipment already has a compatible 12V battery or regulated supply and can provide the actuator’s rated/peak current. Confirm real battery voltage range, charging conditions, transients, controller compatibility and wiring rather than assuming every vehicle or battery system is equivalent.
Conclusão
Choose 12V or 24V from the complete electrical and mechanical architecture. Voltage affects current and voltage-drop planning, but the selected actuator’s load, speed, duty cycle, controls, feedback, environment and mounting determine whether the configuration fits the application.
Use current 12V actuator product evidence when the equipment uses a compatible 12V architecture. Do not infer automotive, marine, battery or reliability suitability from voltage alone.
Use current 24V actuator product evidence when a 24V architecture fits the power and control design. Do not infer higher performance, longer cable capability, synchronization accuracy or PLC compatibility from the voltage label alone.
Keep the fundamental relationship: Potência = Tensão × Corrente. Apply it with the actual actuator current, harness resistance, controller limits and working conditions. Final performance and reliability require configuration-specific validation.
For a project review, provide the required load, stroke, speed, duty cycle, available supply, cable length, controller/feedback, mounting and environment so suitable 12V or 24V candidate configurations can be compared.
Obtenha Insights de Especialistas em Controle de Movimento Industrial
Selecionar o atuador linear elétrico ou coluna de elevação é crítico para o desempenho do seu projeto. Como um fabricante profissional de Controle de Movimento & Automação, nossos engenheiros ajudam você a personalizar a capacidade de carga, comprimento de curso e classificações IP com base em sua aplicação específica. Compartilhe seus requisitos técnicos para uma solução sob medida.
A ActuLift apoia a personalização de ponta a ponta, desde o design estrutural e parâmetros de curso até branding e acabamentos de carcaça, ajudando você a construir uma identidade de marca poderosa.
Resposta Rápida & Prototipagem
Entendemos a importância da rapidez na aquisição B2B, utilizando fluxos de produção otimizados para garantir respostas eficientes desde o desenvolvimento de amostras até a entrega em massa.
Quality Documentation & Traceability
Quality and traceability requirements vary by project. Ask ActuLift for the applicable inspection records, product specifications, drawings and available compliance documentation for the selected model and order.